ENGINEERING CASE STUDY · PUBLISHED
4-DOF Robotic Cocktail System
A Bluetooth-controlled robotic arm developed to automate cocktail preparation, shaking, cap handling, and serving.
Project objective
Design an automated cocktail-serving system capable of reproducing coordinated preparation motions through a compact four-degree-of-freedom robotic mechanism.
Robotic mechanism
The system combines a multi-axis arm with a purpose-built end effector for positioning the shaker, operating its cap, performing programmed shaking patterns, and controlling the final serving angle.
Bluetooth control interface
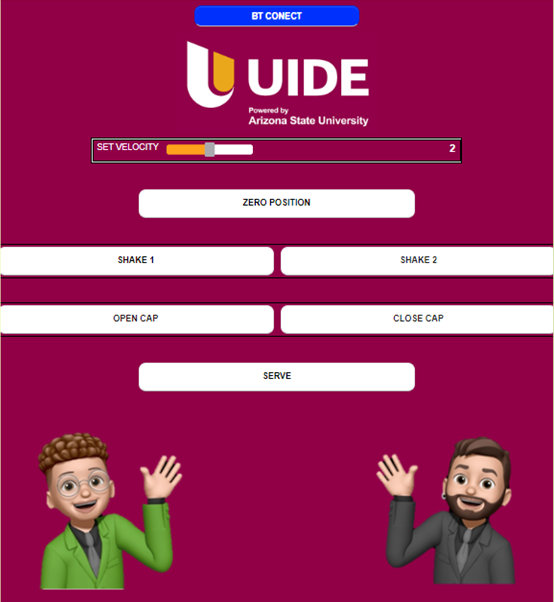
A custom mobile application provides Bluetooth connection, adjustable velocity, zero-position control, two shaking routines, open-and-close cap commands, and a complete serve command.
System integration
Mechanical design, actuator sequencing, wireless commands, and end-effector motion were integrated into a complete demonstration platform capable of executing the cocktail workflow from preparation through pouring.
My role
I developed the robotic system across mechanical design, motion-control integration, prototyping, testing, and the Bluetooth application used to operate the complete sequence.